The cookie settings on this website are adjusted to allow all cookies so that you have the very best experience. If you continue without changing your cookie settings, we'll assume that you are happy to receive all cookies on our website. However, if you would like to, you can change your settings at any time using the Change cookie settings link in the Special menu.
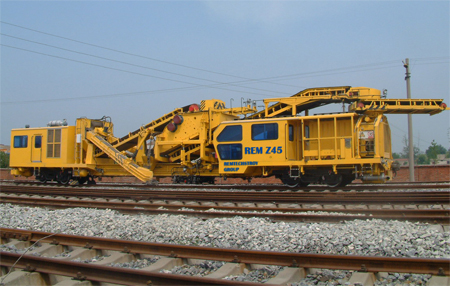
The REM Z45-II ballast cleaning machine undercutter ballast-cleaner is applicable for medium and heavy duty ballast-cleaning operation of railway track bed. Without the need to dismantle rails and sleepers, the achine can excavate waste ballast by excavator chains and then feed the waste to ballast-hopper via lifting guide. The mixed ballast-conveyor belt takes ballast into vibration screen. Clean ballast after screened will be returned to track bed under sleepers through return hopper. The waste is conveyed to slewing conveyor belt via waste conveyor belt, and then feeding to the coupled materials transportation wagon. The waste can also be thrown to one side of track if there are no a bridges or tunnels on project site. When each working mechanism is engaged, the machine can perform continuous operation under its own power at the same time, and complete ballast cleaning of railway track bed. At railway sections required to completely replace ballast, all the waste ballast can be thrown to one side of track or to be directly conveyed to materials transportation MFS wagons.
REM Z45-II ballast cleaning machine - Ballast cleaning machine for tracks - Built for rail networks with narrow gauge and limited loading gauge - Excavation width may be increased by using feeder plates (2.7 – 3.4 m) - Two-level vibratory screening system with changeable screen bases - Bogies with two axles and two retractable support axles for transfer travel - One work cabin and two driver’s cabins - The worldwide REMTECHSTROY GROUP service network
The modification/generation v.2.0 is 2011: REM Z45-2 Total machine hours: 00.000, Meleage: 000.000. Engine: New, production Commins (KTA19-L600). Hydraulics: New production (DE, EC, REM EC). The New REM Cutting Chain assembly: The production in REM plant The REM warranty EC: 12 + 6 (bonus for new customer): 18 months Complete logbook and history (service REM). One owner. Technical comment: REM Worked 000 Shifts YTD. The price is FOB Port of Bulgaria: For Price and More Information Call. +The Optional Broad Gauge Track 1000 mm: The rebuild in REM plant
Drawing
Technical Data, UIC 505-1 cabarite/loading gauge
Track gauge:
1435 mm , The Optional: 1000 mm
Diesel engine CUMMINS KTA19
448kW / 2100r/min
Model:
CUMMINS KTA19-L600, water-cooled diesel engine
Hydrastatic drive whele working
Generatr set rated output:
250 kW
Demension Specification
Overall length:
24938 mm
Maximum wight:
3300 mm
Maximum height:
4650 mm
Distance between pivot bogie/centers:
17100 mm
Bogie wheel base:
2000 mm
Number of bogies:
2
Mass, ton, not more:
88 ton
Speed
Maximum operation cleaning speed:
0 ~ 500 m/h
Maximum speed under own output:
100 km/h
Maximum speed in a train composition:
120 km/h
Minimum curve radius
Minimal radius of curve negotiated (working):
250 m
Minimal radius of curve negotiated (running):
120 m
Excavator width:
3900 mm, 4200 mm, 4400 mm
Excavator depth:
under sleepers 200mm-450mm
Ballast excavating units:
Excavator width:
3900 mm, 4200 mm, 4400 mm
Excavator depth:
under sleepers 200mm-450mm
Maximum output:
over 450-500 m3/h
Track holding system:
Maximum shifting:
+/-220mm
Photos REM Z45-II ballast cleaning machine undercutter:
REM options:
FREE of charge REM options included in the contractual price as a standard delivery for the end customer: +Free option 1: The REMTECH to train Railways technicians on machine operation and maintenance in the REMTECH manufacturer plant. +Free option 2: The REMTECH to train Railways technicians on machine operating and maintenance in the country customers. +Free option 3: Technical documents for operating, maintenance and repairs as well as spare parts catalogues in English language. +Free option 4: A ll the plans and list of spare parts on CD. +Free option 5: Adjustment of the machine as per the requirements of the Buyer. +Free option 6: 1 set WC Cutting Chain Assembly REM Z45. +Free option 7: Air - conditioning system in the control cabins. +Free option 8: Devices for testing the printed circuit boards - REM PCB of the machine. +Free option 9: E quipped with 4 buffers CAT A according to UIC 526-1.
Customer Login and Inquire About Price
Customer Login and prices To be able to access our prices, delivery terms, catalogs, brochures, technical specifications, videos, certificates, photos and pdf, you have to be registered, logged in and be a member of the "PRO Membership levels - www.tampers.org": - End customer PRO - owner of railway mechanization; - REM Agent/Dealer *P&T* (Wholesale I); - REM Agent/Dealer LT *P&T* (Wholesale I); - Wholesale PRO *P&T* (Wholesale II); - REM Agent/Dealer UA *P&T* (Wholesale III); - Wholesale KZ *P&T* (Wholesale III); - Customer KZ *P&T*; - REM Agent/Dealer {not EU} (Wholesale I); - Wholesale PRO {not EU} (Wholesale II); - Wholesale {not EU} (Wholesale III); - Customer {not EU}.
Not a tampers.org user yet? Register now free-of-charge and without obligation: 1) Load in your browser: www.tampers.org ; 2) Registration -> press " Register" top right or for Authentication -> press "Sing in", enter USED ID/Pass; To receive the Customer Login Name/Pass and Authentication for PRO Membership levels {www.tampers.org}, must necessarily send fax inquiry on company form with signature and stamp to the attention of Sales Department "REMTECH" or REMTECHSTROY GROUP, fax: +359 52 319990 or e-mail: sale@remtech.info or or contact directly the REMTECH representative in Your country.
ADDITIONAL OPTIONS against assitonal payment at client's desire: +REM Laser: Automated system for control of the situation at the rail beam running the Cutting Chain. Laser sensor for supervision and control of the depth of sifting. +REM CCTV: Video surveillance system. Protective function: Warning upon attempts for penetration by foreign persons during the stay of the machine at stations. The video surveillance option may be used for visual survey/inspection of the machine and protections of its most important parts – cabin, operating elements, power cables and electronics. +REM Pilot GPS: System for collection and recording of control data and operating parameters of the main operating elements, as well as parameters of motion and determining of current location of REM Z45 in real time through a GPS. +REM Radar: System for safety and protection of the working staff and team servicing the REM Z45 operation, through automated location of objects moving along the rail road through a radar technology. Range of location of trains at a distance farther than 5000 meters. Velocity of moving of an object 10-300 km/h. Time for reaction of the radar and issuance of a warning signal: up to 15 seconds. +REM Georadar Measurements - RGM : Automated system for georadar (ground-penetrating radar) roadbed inspection REM GEOSCANNER is intended to provide the following solutions: - determining thickness and lithologic structure of the ballast bed discriminating the fouled subgrade layer and increased moisture areas; - localizing the upper boundary of roadbed soils and their lithologic structure; - discriminating low coherence areas in the roadbed featured by reduced density and increased moisture; - revealing foreign objects in the roadbed and ballast bed, viz., cables, buried track superstructure components (crossties, rails), large stones, etc. - localizing engineering facilities; - localizing areas with laid geotextile or expanded polystyrene; - inspection of quality of the accomplished track overhaul. The objective of this method of investigation is to determine the pollution within the ballast bed and the mixture of ballast with the subsoil. It is also possible to locate water traps. The qualitative measurement of the water content in the subsoil enables the existing drainage quality to be assessed. By comparing the condition before and after the rehabilitation, it was possible to make a quality assessment of the formation rehabilitation work performed.
Technology The REM Georadar Measurements - RGM is state of the art for GPR systems. It is based on more than 20 years of working experience with GPR and it is the product of continuous development and adaptation to the specific requirements of our international railway customers. - Survey of tracks of any length or even of the entire railway network. - High speed survey of 900 track kilometres per run. - 2,000 scans per second. - Each channel is controlled separately, allowing even speeds of more than 300 kph. - Three or even more longitudinal profiles provide track cross section at any position. - Measurement only between sleepers to avoid disturbances. - Scan distance between 2 cm and 60 cm for coping with all customer requirements. - Antennae frequencies between 100 MHz and 900 MHz for high resolution in all depths. - System-embedded positioning radar for accurate allocation of all measuring data along the entire track. Accuracy better than 0.5 m. - System-integrated DGPS for reception of world wide satellite systems GPS and GLONASS. Correction data for GPS via GSM or EGNOS for an accuracy better than 0.3 m. - Displaying of survey track and all constructions in Google Earth. - System-integrated Video-camera for continuous view of survey track. - System-specific Viewer-programme for display of the GPR results related to the geotechnical conditions of the track, including Google-Earth-view and Video-camera-pictures.
The RGM survey provides continuous details of track conditions. Railway engineers obtain important information about: - Thickness of track bed and sub-ballast layer. - Sections with clean or fouled ballast. - Drainage problems in ballast bed and undertrack. - Mapping of load-bearing problems (settlements, ballast pockets). - Anomalies along the track. RGM - Radargram with longitudinal profile of track section The picture shows a track section between km 11.100 and km 11.700. In that section the ballast has been renewed to a depth of 0.3 m. Below, there is fouled ballast (dark grey layer). Ballast settlements indicate insufficient bearing capacity of the sandy formation. Below the sandy layer, a drilling at km 11.450 is showing peat and clay. The picture shows a track section between km 1.300 and km 1.900 (see horizontal axis). The vertical axes represent both depth in m related to top of sleepers and travel time of the waves in nanoseconds. In that section the ballast has been renewed to a depth of 0.5 m (pale grey layer). Below, there is fouled ballast (dark grey layer). Ballast settlements can be seen between km 1.460 and 1.570. This is an indication for insufficient bearing capacity of the sandy subgrade (yellow layer). Below the sandy formation there is clay to be found. Between km 1.600 and km 1.900 the clay layer is almost adjacent to the ballast bed. In this section, a well working drainage is important. Otherwise water will remain inside the track, leading to eventual stability problems of the track. The picture shows crossings at km 1.370 and km 1.870. Drillings have been carried out at km 1.550 and km 1.740. In both cases ground water has been found in a depth of 1.2 m.
Quality control of track construction Track construction is always very cost-intensive. That's why at least the result should add up. Our quality control is continuous and exact. And we provide information about: - Quality of new ballast (cleanliness). - Thickness of track bed and sub-ballast layer. - Efficiency of track drainage. - Evenness of ballast-bed bottom or sub-ballast layer. - Track cross-section. RGM - Viewer showing the geotechnical track conditions. Diagram of long-profiles, cross-section; Video as well as track course on Google-Earth
Examples cables, pipes, objects Example for a cable crossing at km 14.094 in the formation in a depth of 1.20 meters. Example for a cable crossing at km 13.999,5 at the ballast base in a depth of 0.42 meters. Cables, pipes and objects in various depths between 0.16 m and 1.36 m along a range of about 30 meters.
+REM 3D RAIL - perfected a solution for 3D machine control. Use Rem3DRail for controlling rail ballast cleaning machine. The universal solution for 3D machine control and for: - Improved return on investments (ROI); - Higher precision; Total station or global positioning system (GPS) via satellites, using GPS receivers. In combination with Rem3DRail, you can operate many position indicators, such as: Total station: - Leica - Spectra Precision - Topcon GPS solutions: - Topcon - Leica - Trimble - Javad - Ashtech - Spectra Precision - Sokkia REM 3D RAIL ballast cleaning machine to within a few millimetres of alignment. REM 3D RAIL allows operators to focus on other systems of the machine and dramatically reduces survey costs while increasing accuracy.
Input data Rem3DRail works well with various models, for example, rail geometry and horizontal and vertical alignment with cross-slope. Input data is transmitted directly from an office computer, from a portable computer on the machine, or from a GSM solution to Rem3DRail. You can also enter data manually by using the Rem3DRail keyboard.
Rem3DRail - The ultimate field surveying software and input units
Rem3DRail is compatible with various formats via surveying and design applications for PCs, for example: - DXF - DWG - ASCII - Land-XML - AnPakke - Excel
One unit in the operator’s cab Rem3DRail is housed in one unit, including an 8.4” high-resolution color display. An optional keyboard, light bar, and alarm are also available.
High Precision Rem3DRail continuously determines exact positions of machines’ mechanical equipment by: - Reading distances and angles in relation to the total station, or - Reading coordinates received from GPS receivers.
Position continuously displayed The display shows updated information about the section (chainage) offset, cross-fall, and vertical deviations. Operators can instantly and easily get information on current data, such as angles, distances, and coordinates.
3D control You avoid problems such as vertical curves, cross-slope transitions, and changes in width—thanks to Rem3DRail’s 3D machine control. Rem3DRail always adjusts the machine’s position or its moving tools, under all conditions—regardless of surface appearance or characteristics.
Safer working environment You increase work site safety because no one is needed outside the machine to check the position. Rem3DRail reduces idle time and unnecessary equipment deterioration. Fatigue and risk of injuries are also reduced.
Improved ROI Rem3DRail considerably cuts machine and labor costs. No job is too small for Rem3DRail, which enables: - Increased production output - Higher precision - A reduction in use of construction material - Decreased staffing needs Guarantee Rem3DRail comes with a two-year guarantee on component parts. You can extend the guarantee through a service contract.
+REM R/C (Remote Control) - Remote control of REM Z45 ballast cleaning machine undercutter. Actuating and stopping of the operation process. The remote control of the situation at the rail beam running the Cutting Chain. Control of Excavator width. Emergency stop of the machine. +REM Pilot RM-Z - The REM Pilot RM-Z control and measurement system intended for operation control of the parameters of ballast sifting. During the process of work one measures, processes and output on the screen of the industrial computer of data allowing the machine operator to control the performance of the operation of the ballast cleaning machine undercutter. Using the system allows: - increase of the productivity; - avoid failures;- improve the quality of ballast cleaning; - to improve the geometry of the road after cleaning; - to considerably facilitate the work of the operator; +REM Doctor ODS (On-line Diagnostics System) - The On - line diagnostics system can be used in all models of REM mechanization with the purpose of control of the operation status and operation assessment of the technical status of main units and apparatus, guarantee and post – guarantee operation control by a REM servicing centre. The systems gives opportunity for archiving of parameters liable to diagnostics, prognostics on the working capacity and the motor capacity of railway mechanization in general for the whole machine and separately of each unit and apparatus. The system integration with REM Pilot GPS system, gives opportunity for creation of a fully automated working positions ( railway enterprise dispatcher, direction, servicing centre etc.), gives further opportunity to obtain information in real time mode for the GPS location of the machine, and for the working parameters of operation with the purpose of entire control of the equipment used upon work in “windows”, preventive control and avoidance of failures of expensive units and apparatuses. The system is used for:
operating assessment of the technical status of units and apparatus, and reducing the risk of failure of the equipment upon work in “windows”;
considerable reduction of expenses for servicing and repair of the machine compared to the collection of statistics data upon various operation modes of the equipment, the information collected in the form of database of the system can be used for implementation of scheduled – preventive types of repair;
collection and uniting of the whole information entering from the machine control system, as well as control sensors of the system for diagnostics and sensors of the technological and auxiliary equipment;
registration of the parameters of the technical state of the main units and apparatuses upon various operation modes;
visualization of a detailed and complete “picture”: control and warning information to the machinist and the servicing staff;
GPS / Internet data transmission, alarming upon overload through a SMS;
Emergency stop of the engine (unloading from the overload) upon measurement of critical parameters (risk parameters of operating) of operating units and apparatuses, with continued recording of the parameters after full stop of the machine.
Showing each sensor is visualized in real time in a respective background for each unit, total of three colours: green – normal; yellow – attention; red – overload.
Presently our China Railway Group is intending to purchase ballast regulator(1),tampers(2),track stablizer(1) for carrying out a project in Malaysia. If your company can give us a CIF price and time of delivery on any machine I mentioned above,we...




 REM 3D RAIL allows operators to focus on other systems of the machine and dramatically reduces survey costs while increasing accuracy.


 yellow – attention;
 red – overload.